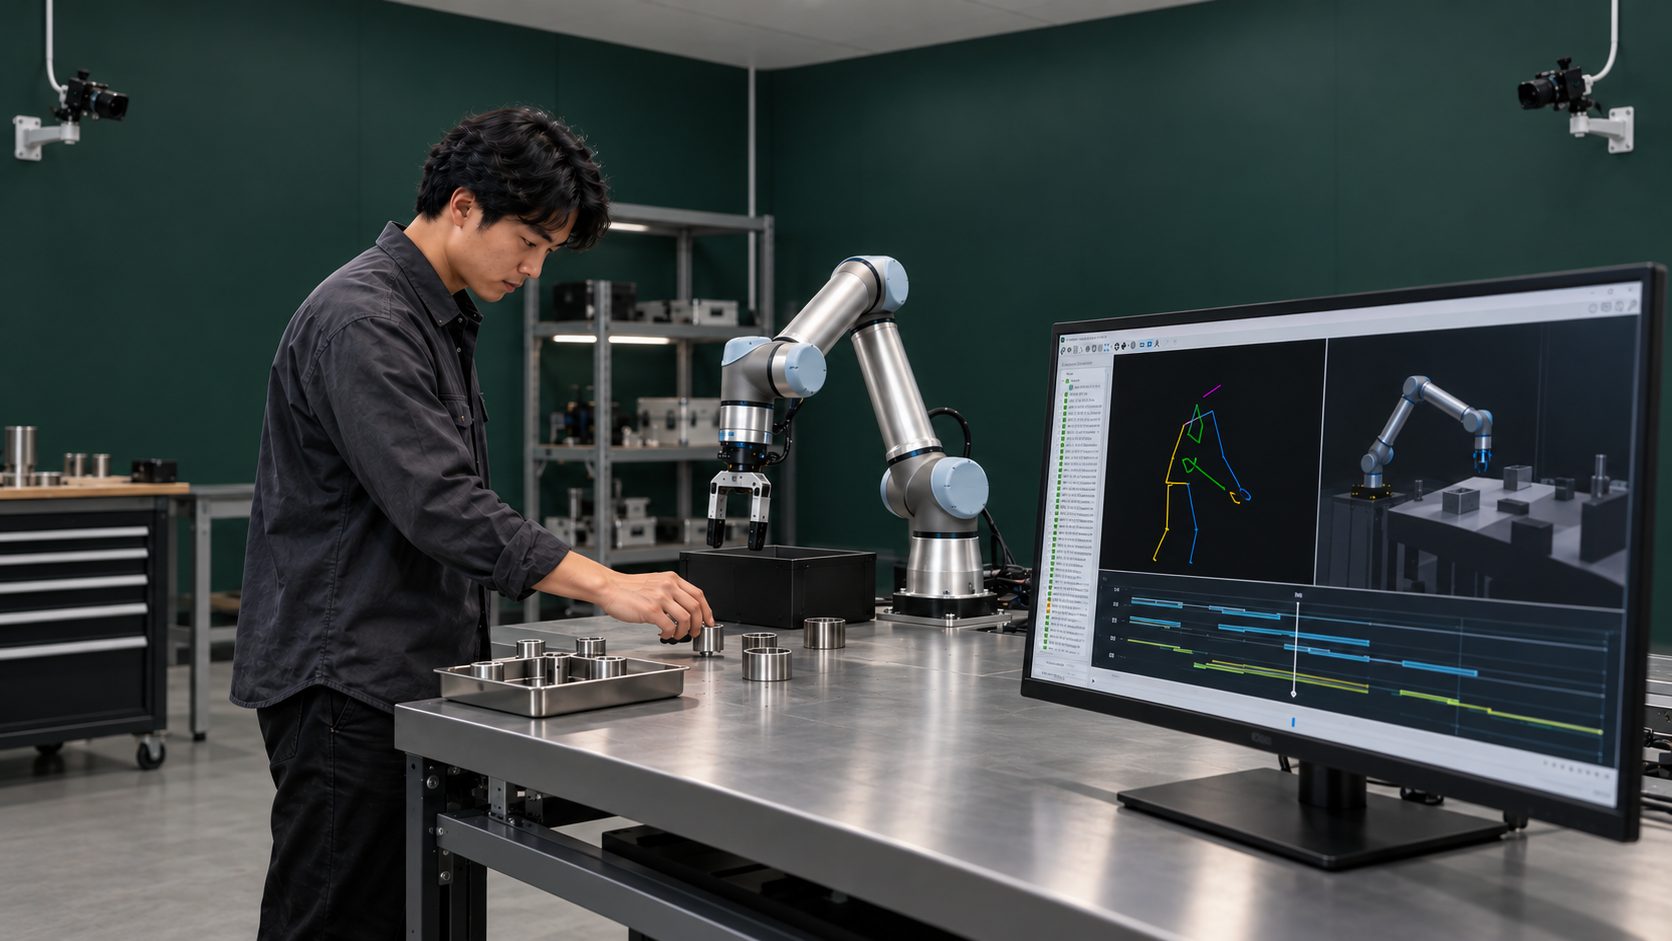
Demonstrate naturally
Move naturally, without markers or suits.
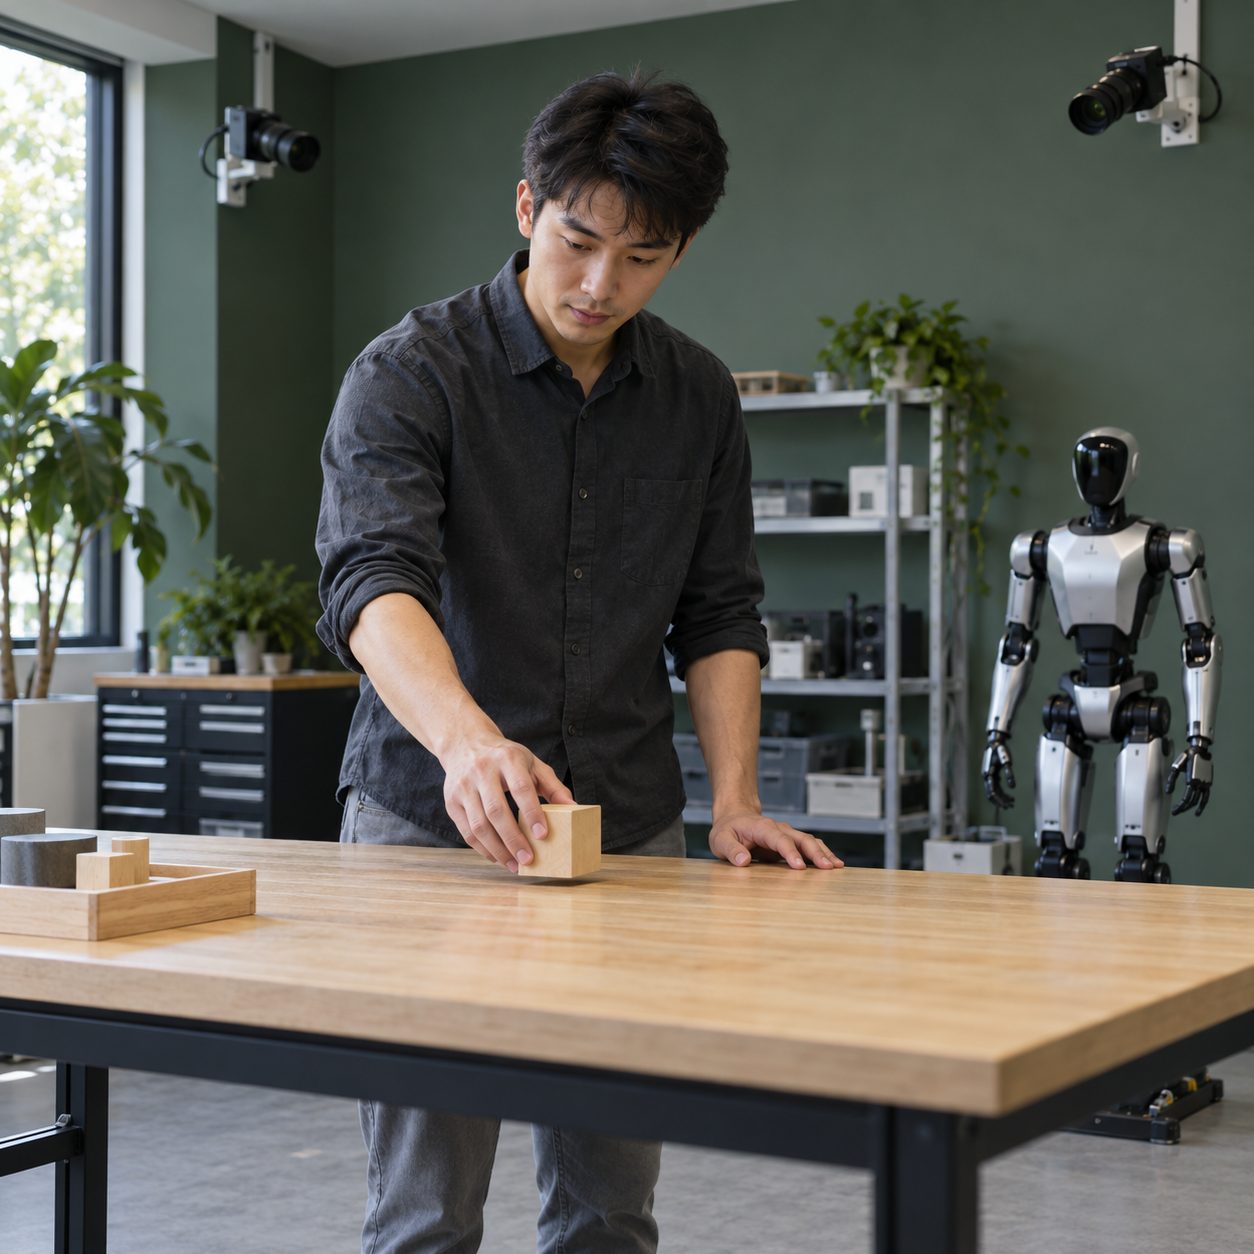
A unified 3D ground truth capture stack.
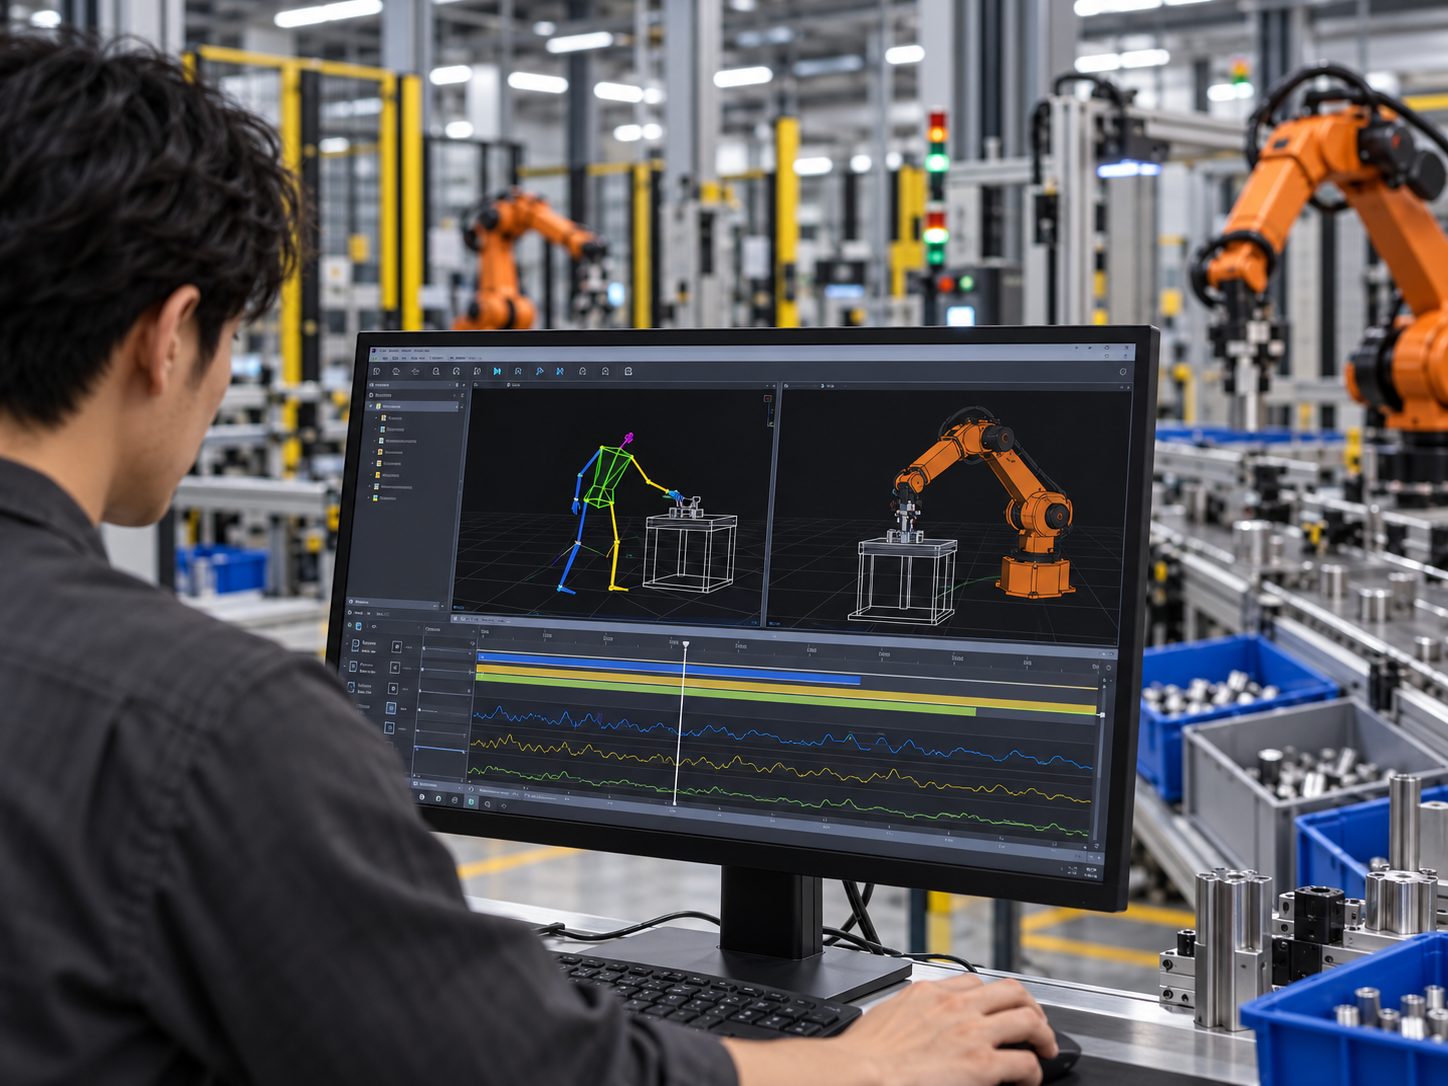
RayKnot transforms human-demonstration data collection by capturing body motion and hands in one single synchronised 3D world.
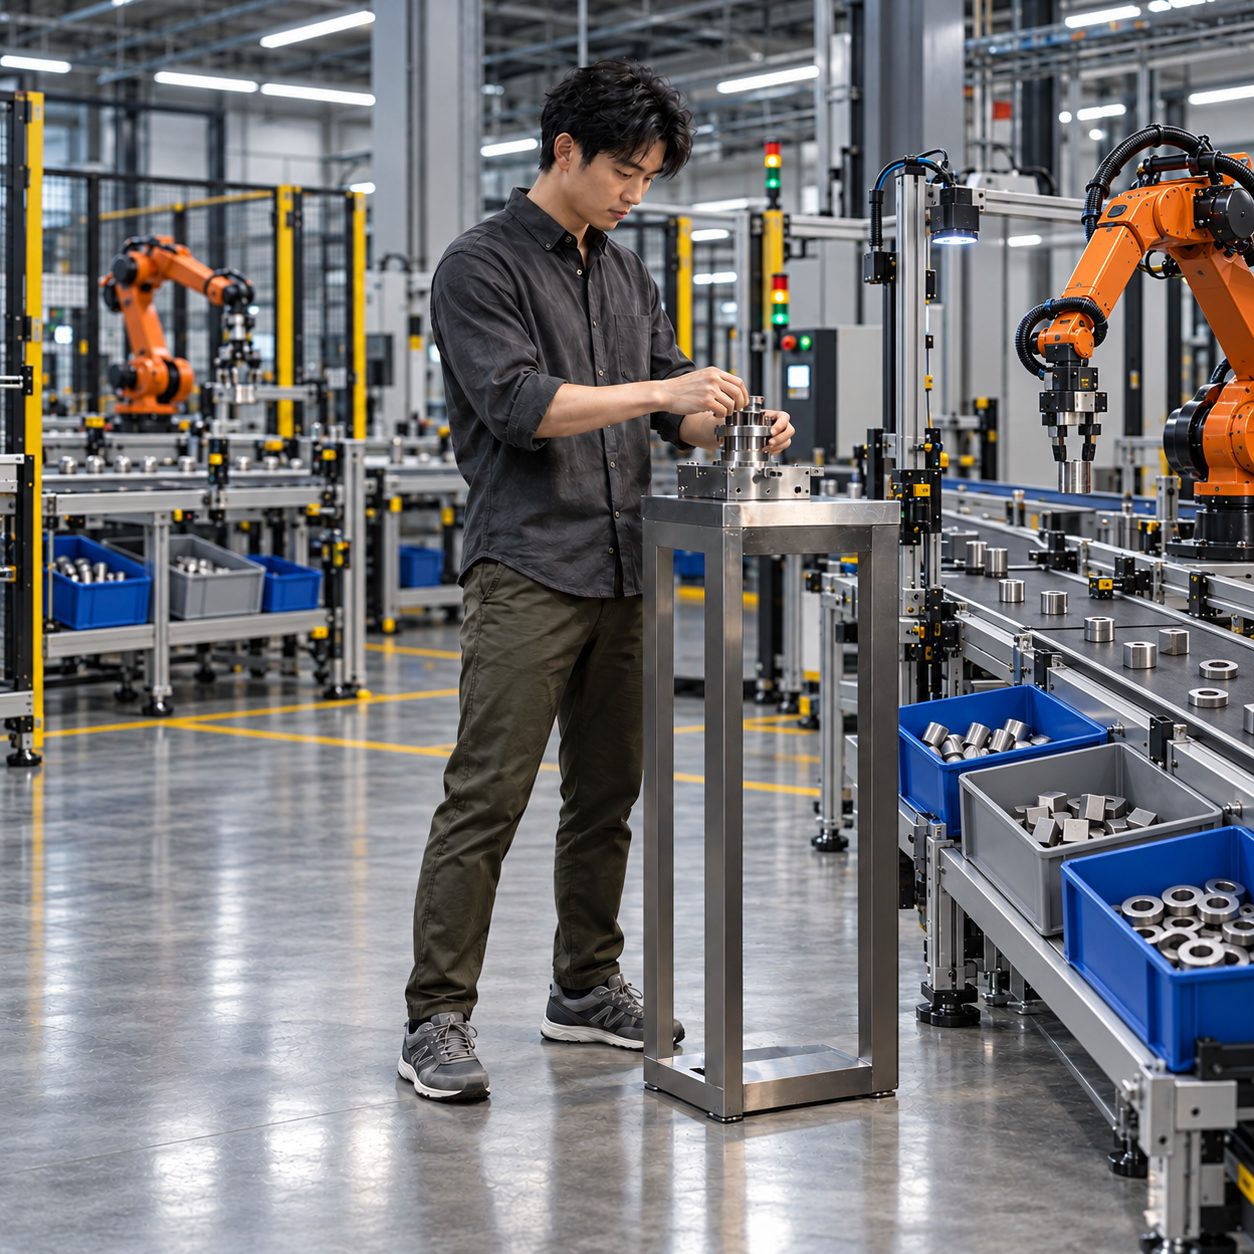
No markers, mocap suits or VR headsets on human subjects. Demonstrators move naturally while RayKnot produces structured, time-aligned data for the purpose of annotation, retargeting, simulation and robot learning.
Fragmented capture systems add setup, synchronisation and annotation work. RayKnot unifies movement data in one time-aligned 3D pipeline.
Move naturally, without markers or suits.
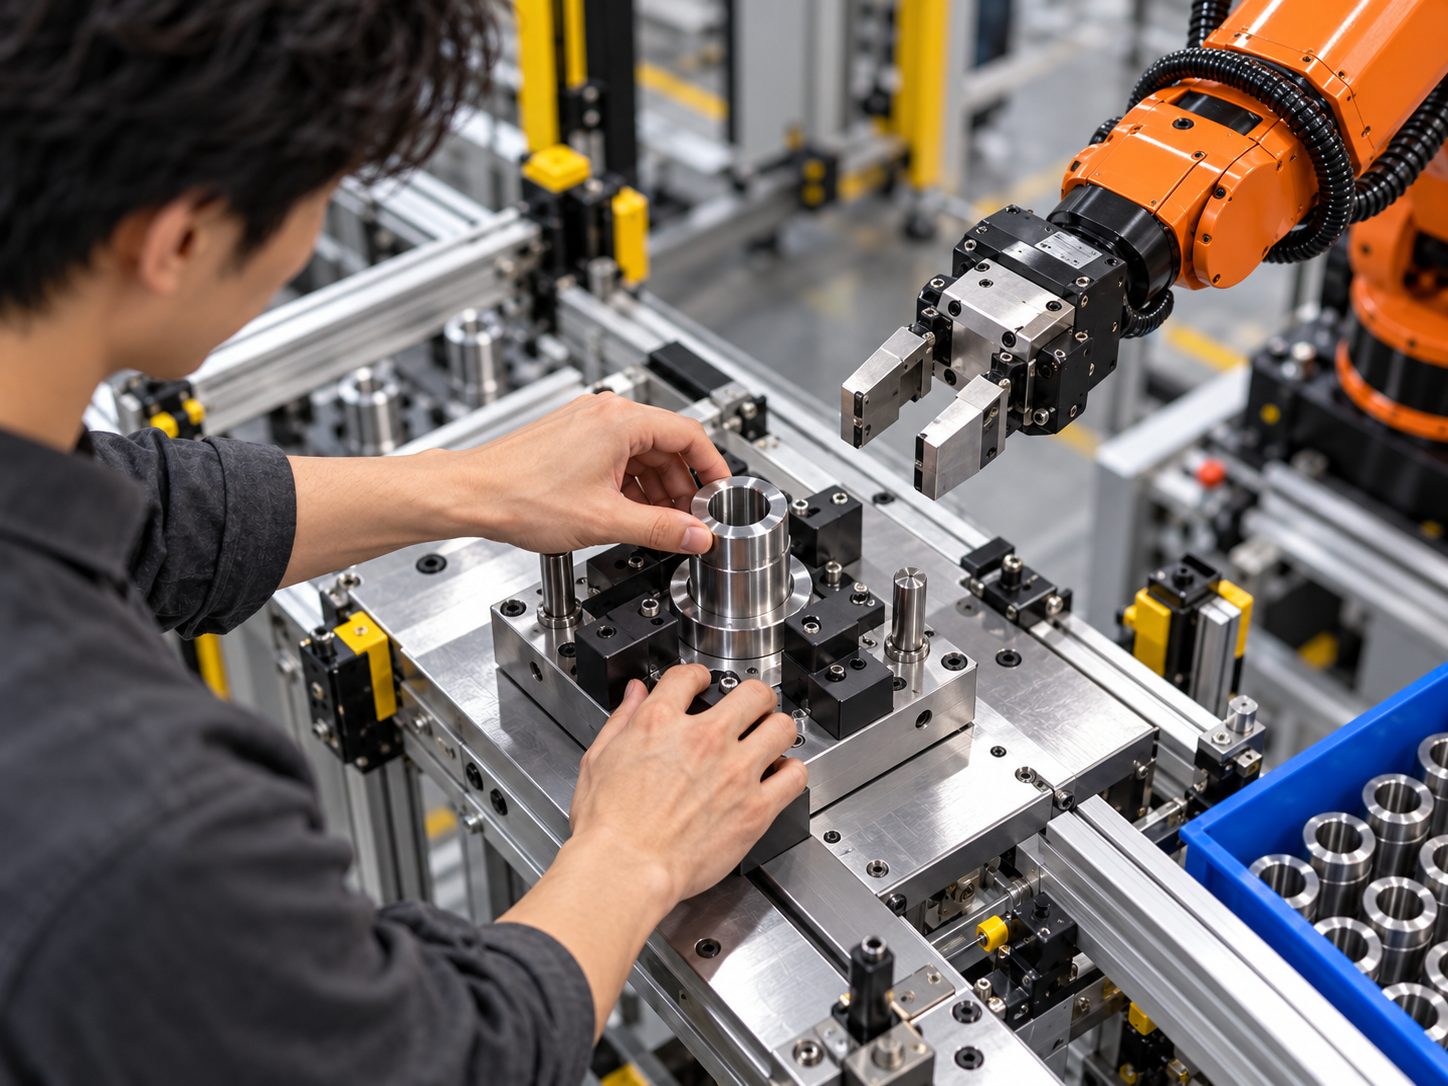
Capture humans, hands and objects together.
Rich ground-truth capture.
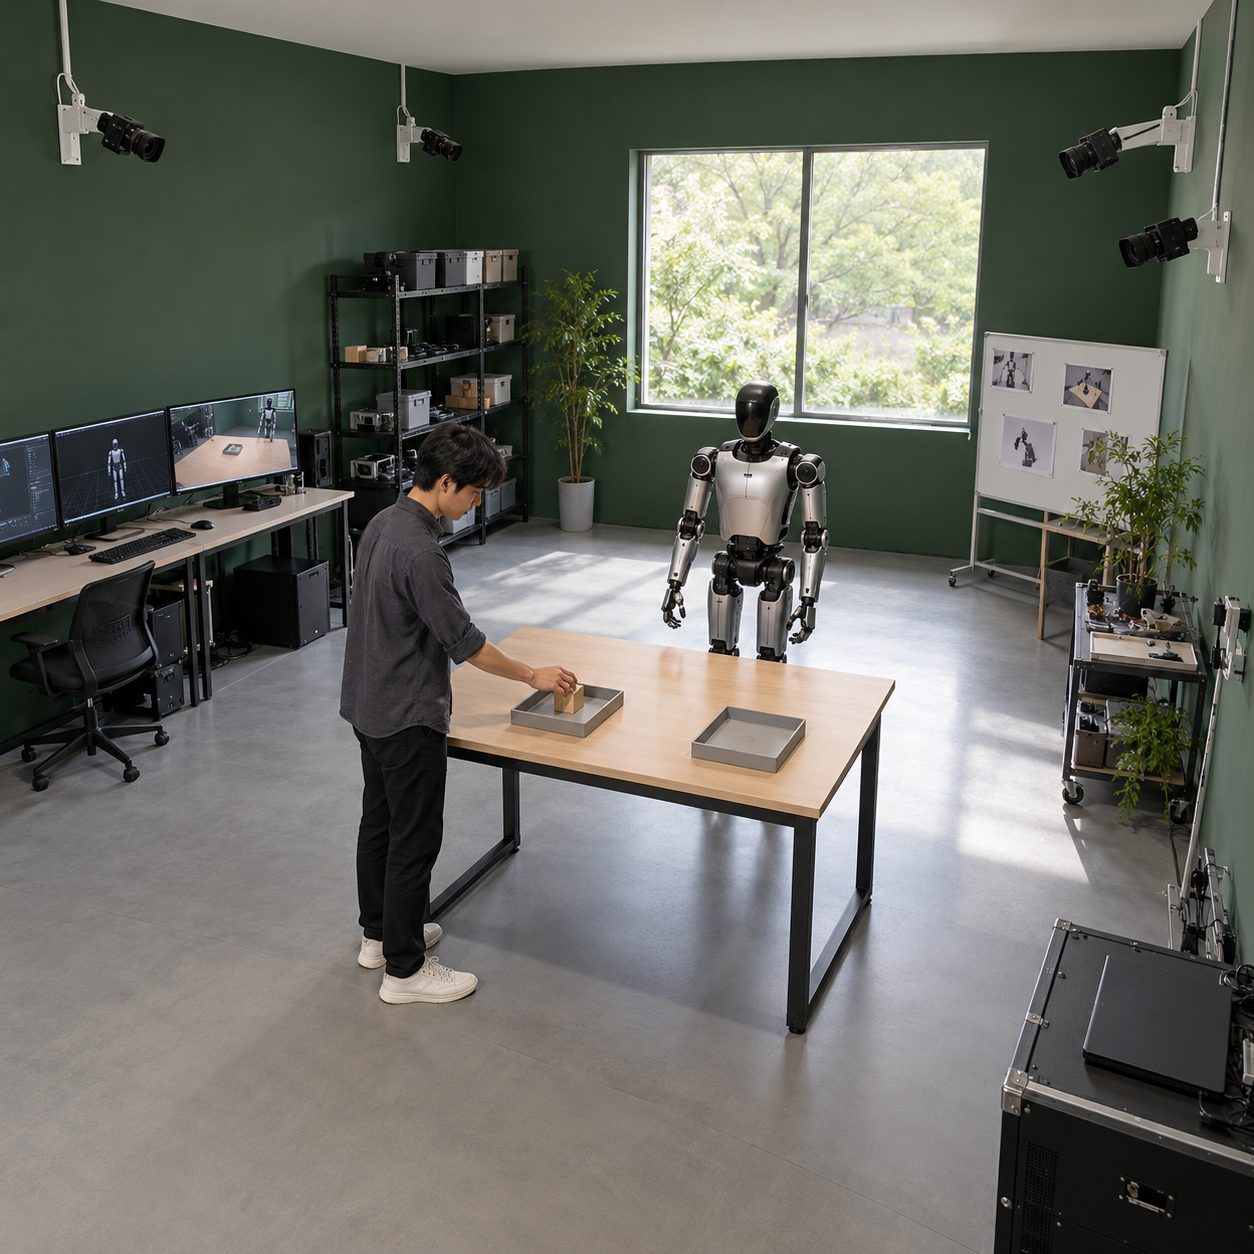
Build synchronised 3D motion and interaction data.
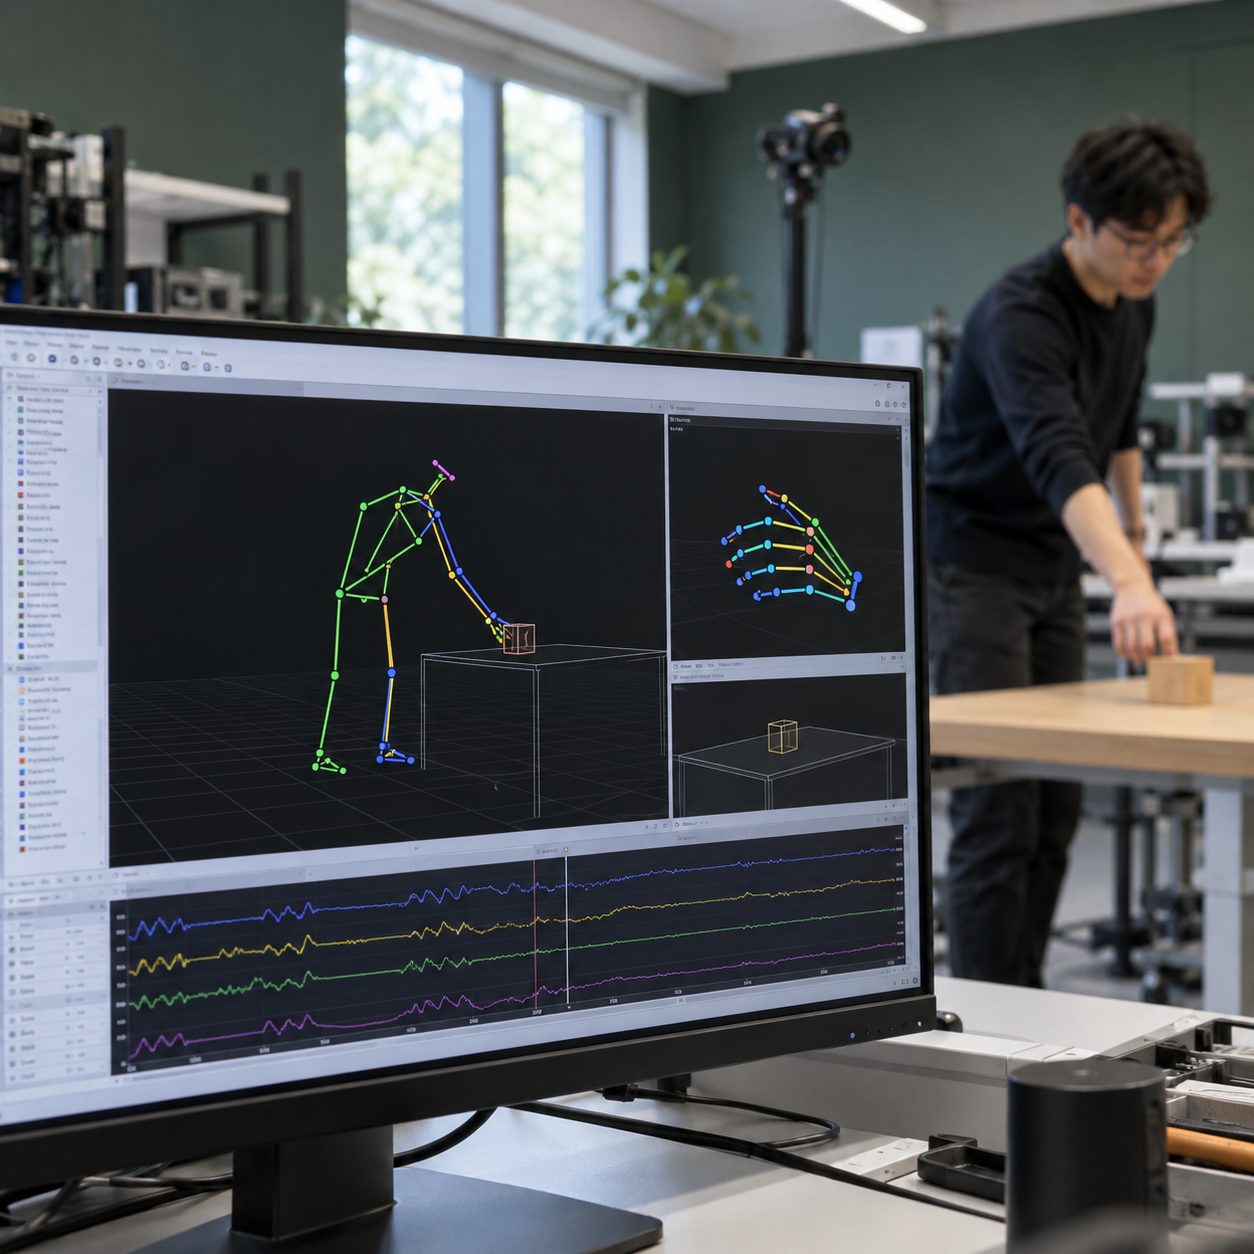
Reduces manual labelling and need for cleaning large volumes of low-information data
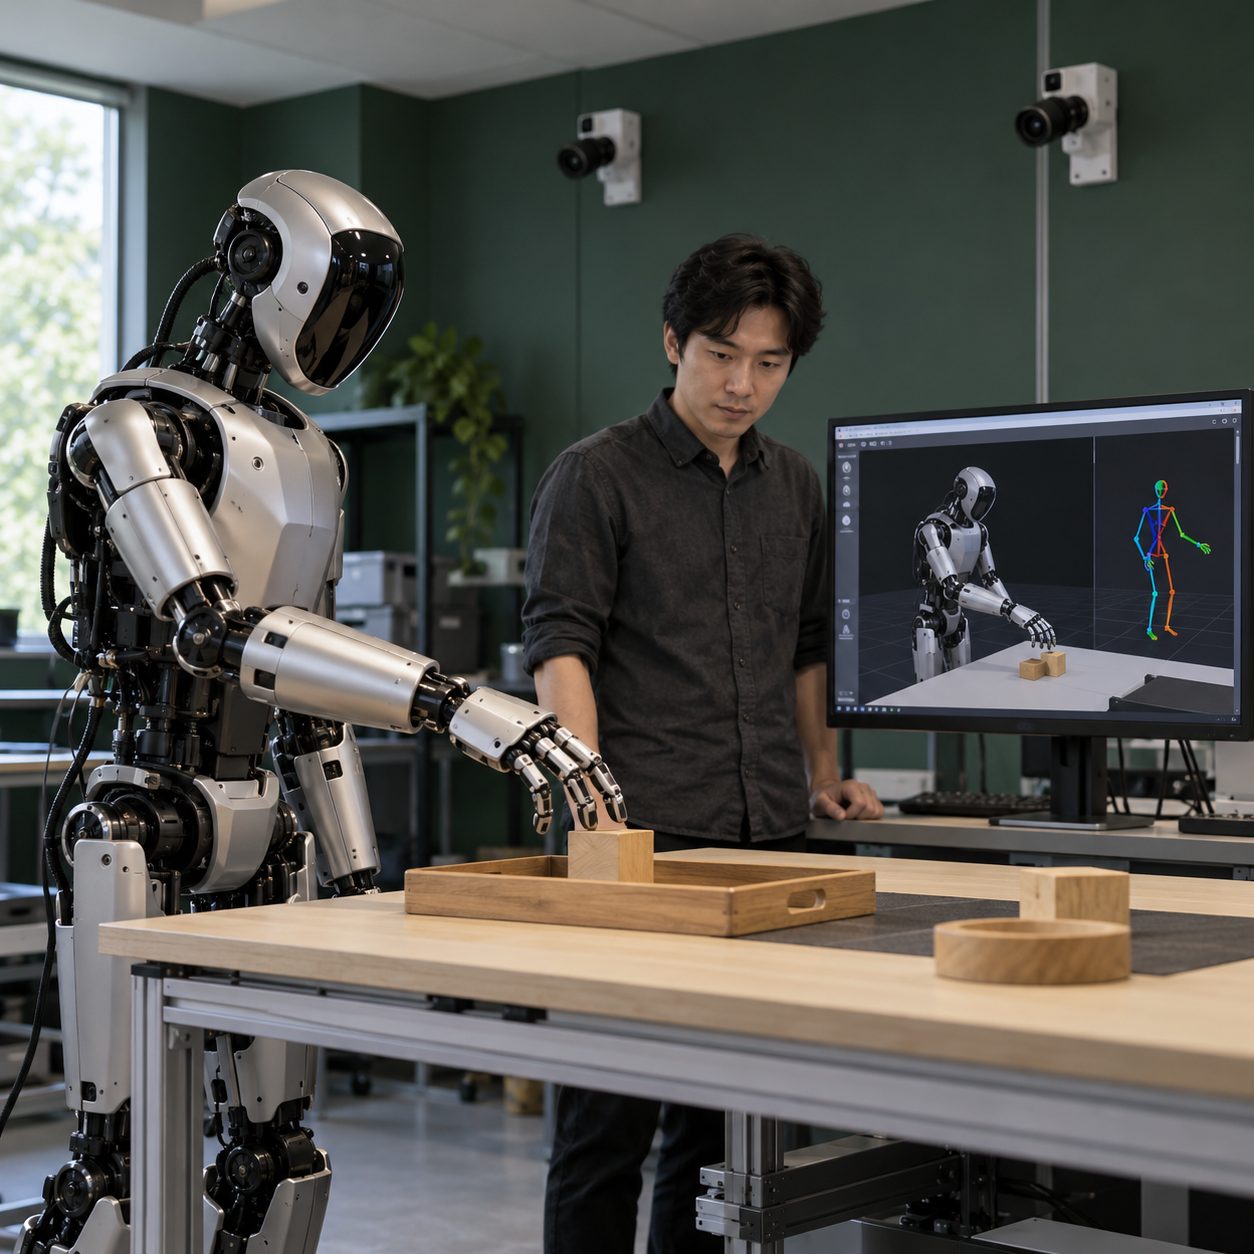
Expand datasets using grounded synthetic variations.
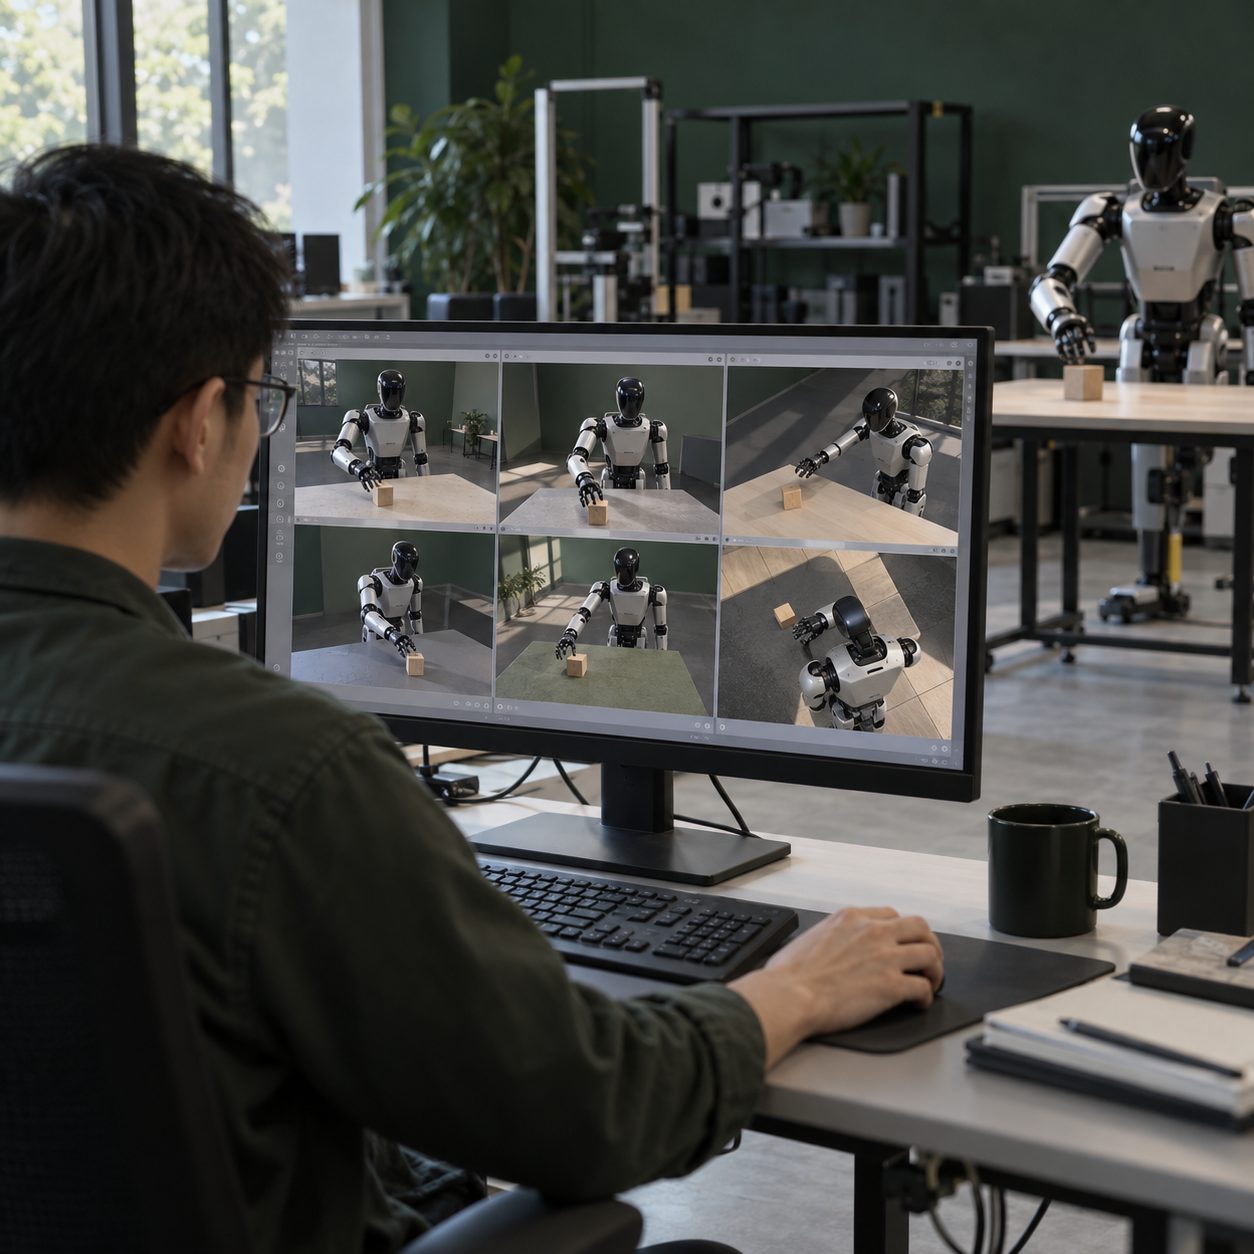
Collect task demonstrations in natural movement.
Prepare structured data for review and labelling.
Increase productivity in downstream data preparation
Expand datasets from measured movement.
Full-body and hand detail in one capture. Rich ground truth capture.
One shared 3D view of interactions.
No markers, suits or VR headsets.
Structured data for downstream workflows
Tell us your robotics workflow. Explore a capture setup for reusable training data.
Book a Demo